Personal robotics / 12 DOF
S.O.L.A.R. quadruped
A walking prototype with a printed chassis, integrated electronics, and solar charging. I designed the structure and component interfaces, assembled the hardware, and verified walking and charging.
Built, wired, and bench-tested
Repository and documentationMechanical design
Chassis and component layout
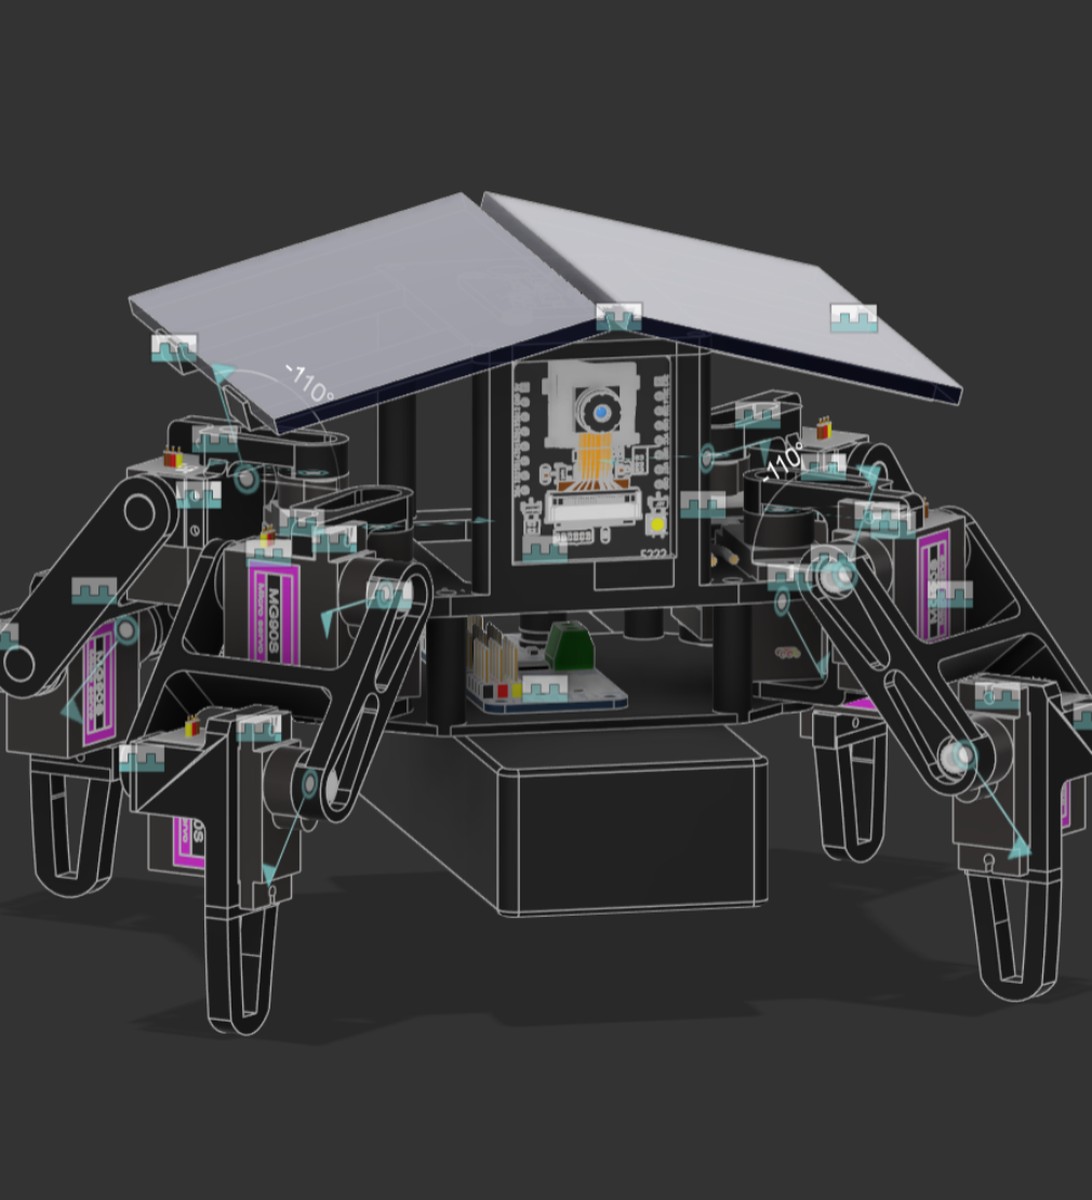
I designed the chassis and component interfaces in Fusion around the servo geometry and the space needed for the battery, electronics, camera, and twin solar panels. PLA-CF frame components carry the hardware; TPU feet add grip and compliance.
Physical integration
Twelve servos, camera, power, and charging
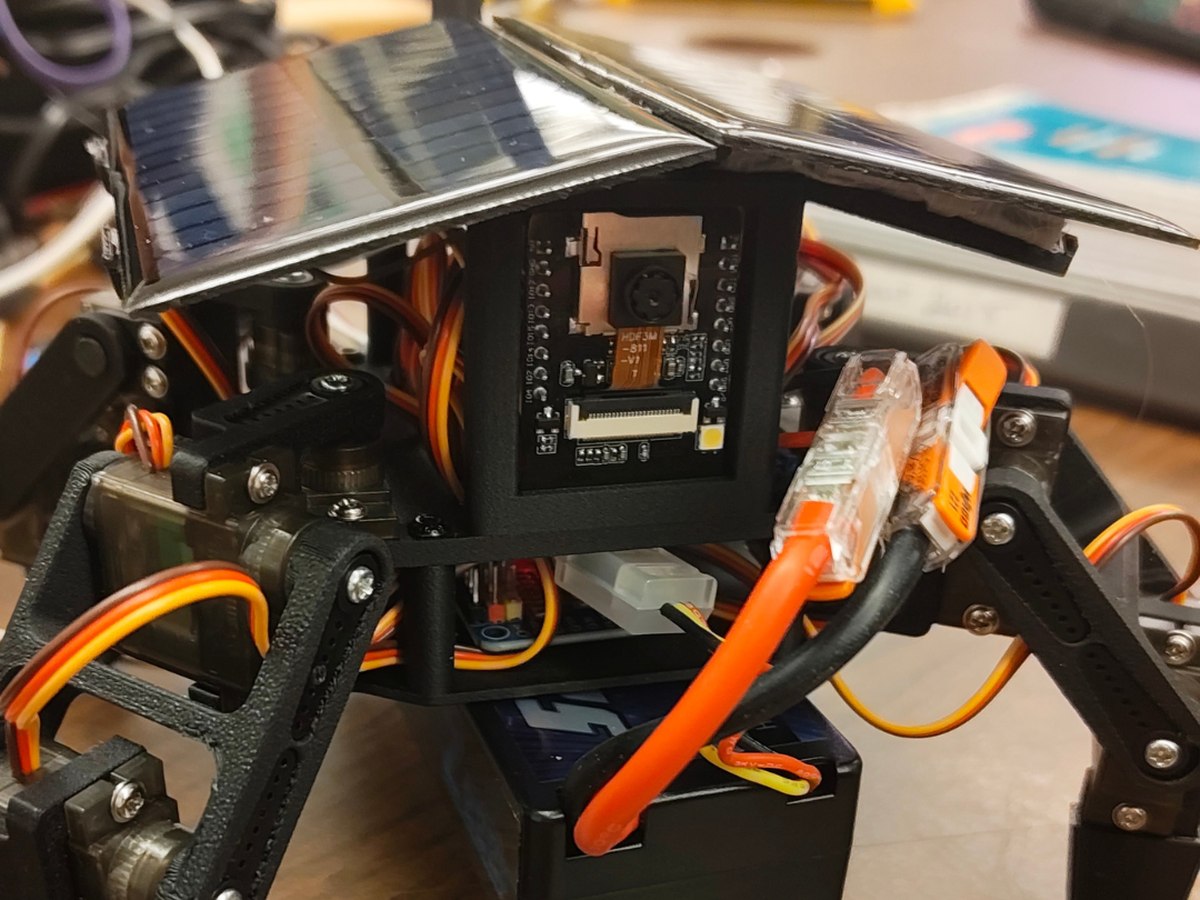
I assembled and wired the controller, sensing, servo, and charging hardware. A close-up of the build shows how these components fit around the printed structure.
The PCA9685 drives 12 servo channels, with three MG90S metal-gear servos per leg.
The ESP32-CAM handles the camera and connects to the servo driver and MPU-6050 over I2C.
Two 5 V 1 W panels feed a 2S solar charger and 7.4 V LiPo battery; a 5 V 5 A BEC supplies the controller and servo rail.
Bench testing
Walking and solar charging
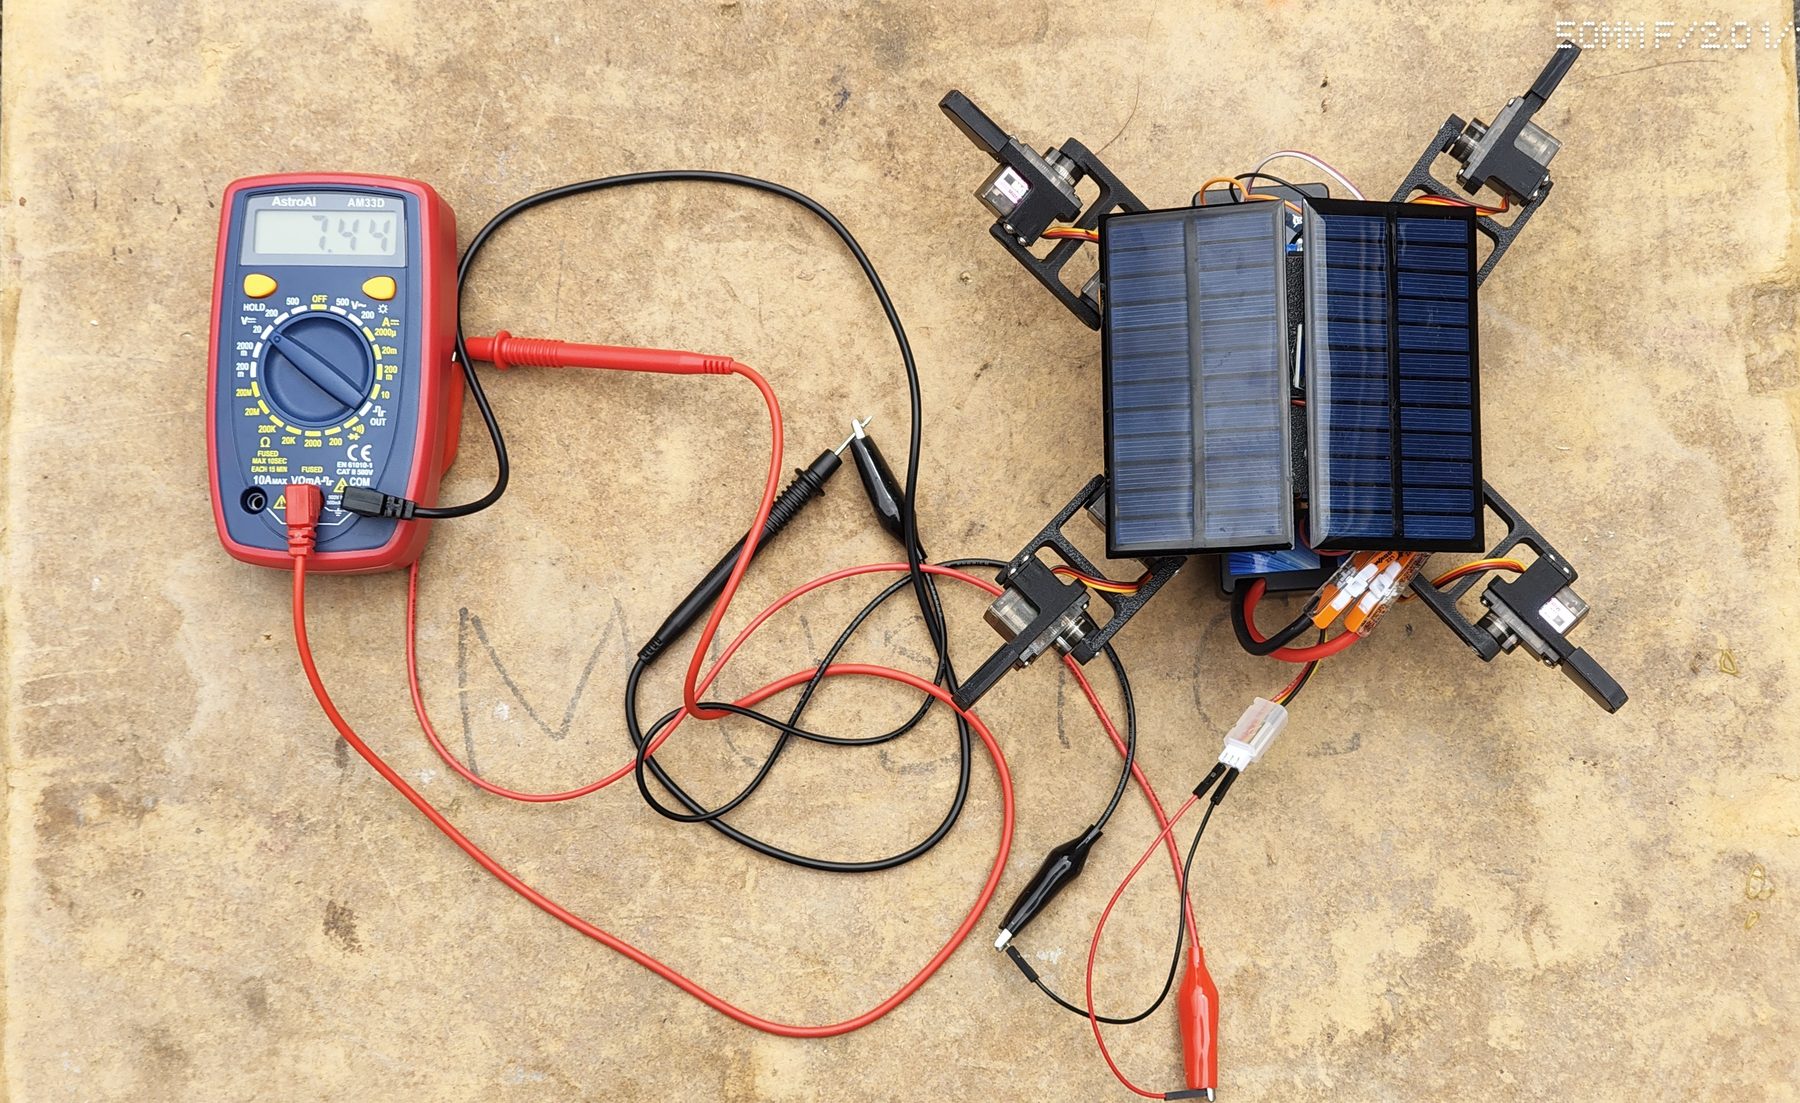
I verified each servo channel and its calibration mapping, demonstrated browser-controlled walking, and confirmed solar-panel charging with a multimeter.